
Drone Research Project
Multi-Robot Operations Interface
An interface for the intuitive and reliable operation of a heterogeneous robotic team with state
monitoring and a safe failure tolerance system.
application
Multi-Robot Operations Interface
In complex, large-scale robotic operations such as mixed fleets of aerial, ground, and marine units, the challenge lies in ensuring seamless collaboration, reliable control and safe operation even for non-expert users. The IROC platform addresses critical use-cases like:
- Coordinating heterogeneous robotic teams (UAVs, UGVs, autonomous boats) to perform mission tasks across different environments (air, ground, water) under unified supervision.
- Real-time state monitoring of all units: tracking telemetry, sensor data, fault conditions, and mission progress, even when operations scale up to many robots.
- Safe mission management including anomaly detection, failure-tolerance, and emergency handling, ensuring robustness in dynamic or hazardous scenarios.
- Enabling operators without deep robotics specialisation to plan, launch and supervise complex multi-robot missions. Lowering the barrier to deploying large robotic formations in real-world industrial, research or civil-protection contexts.
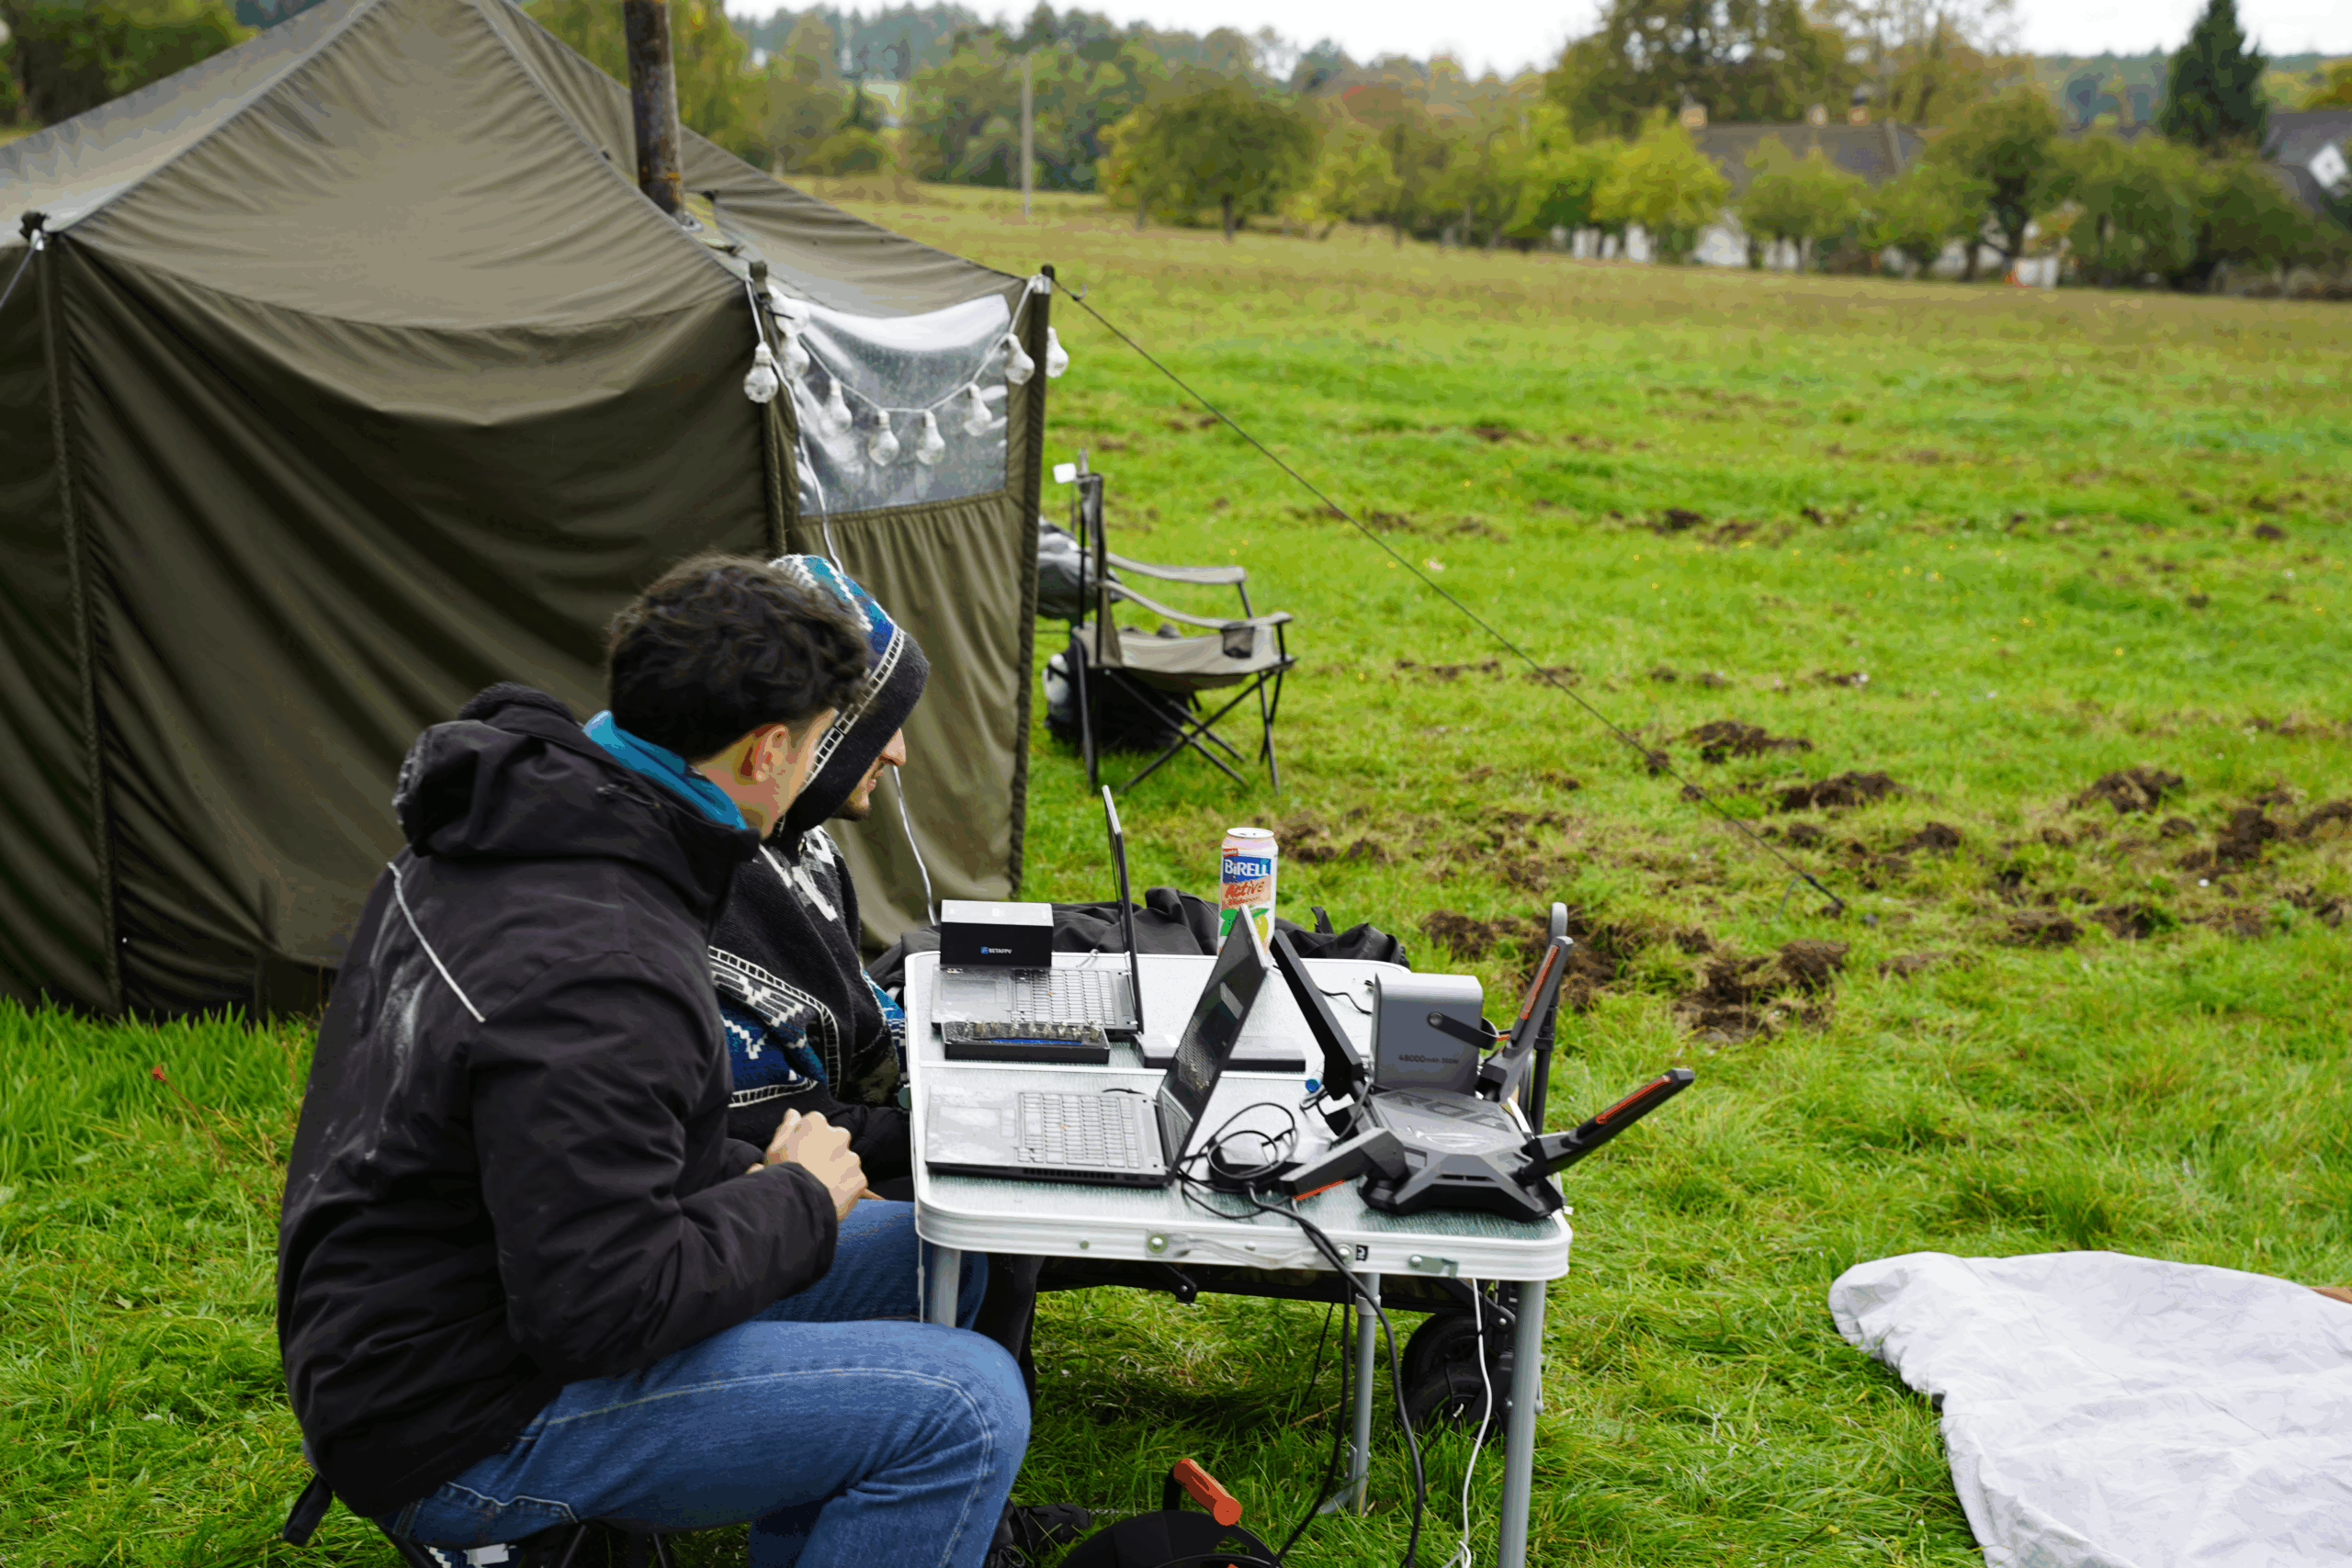
Solution
An Interface For the Intuitive and Reliable Operation of a Heterogeneous Robotic Team with State Monitoring and a Safe Failure Tolerance System
Our solution for the IROC project combines intuitive interface design, robust system architecture and autonomous coordination to enable secure and effective operation of heterogeneous robotic fleets.
- A unified command interface let’s the operator define multi-robot missions, visualise telemetry and sensor data from UAVs, UGVs and unmanned boats, all in one dashboard.
- Built-in failure-tolerance and emergency management systems handle missions safely in real time, detecting malfunctioning units, reassigning tasks and safeguarding mission objectives.
- Autonomous planning and execution capabilities allow the robot team to navigate, cooperate and adapt in varying environments, without requiring specialist-level control from the operator.
- The result: large robotic formations become practical for real-world applications, offering clients scalable and dependable automation for tasks ranging from inspection and monitoring through to coordinated field operations.
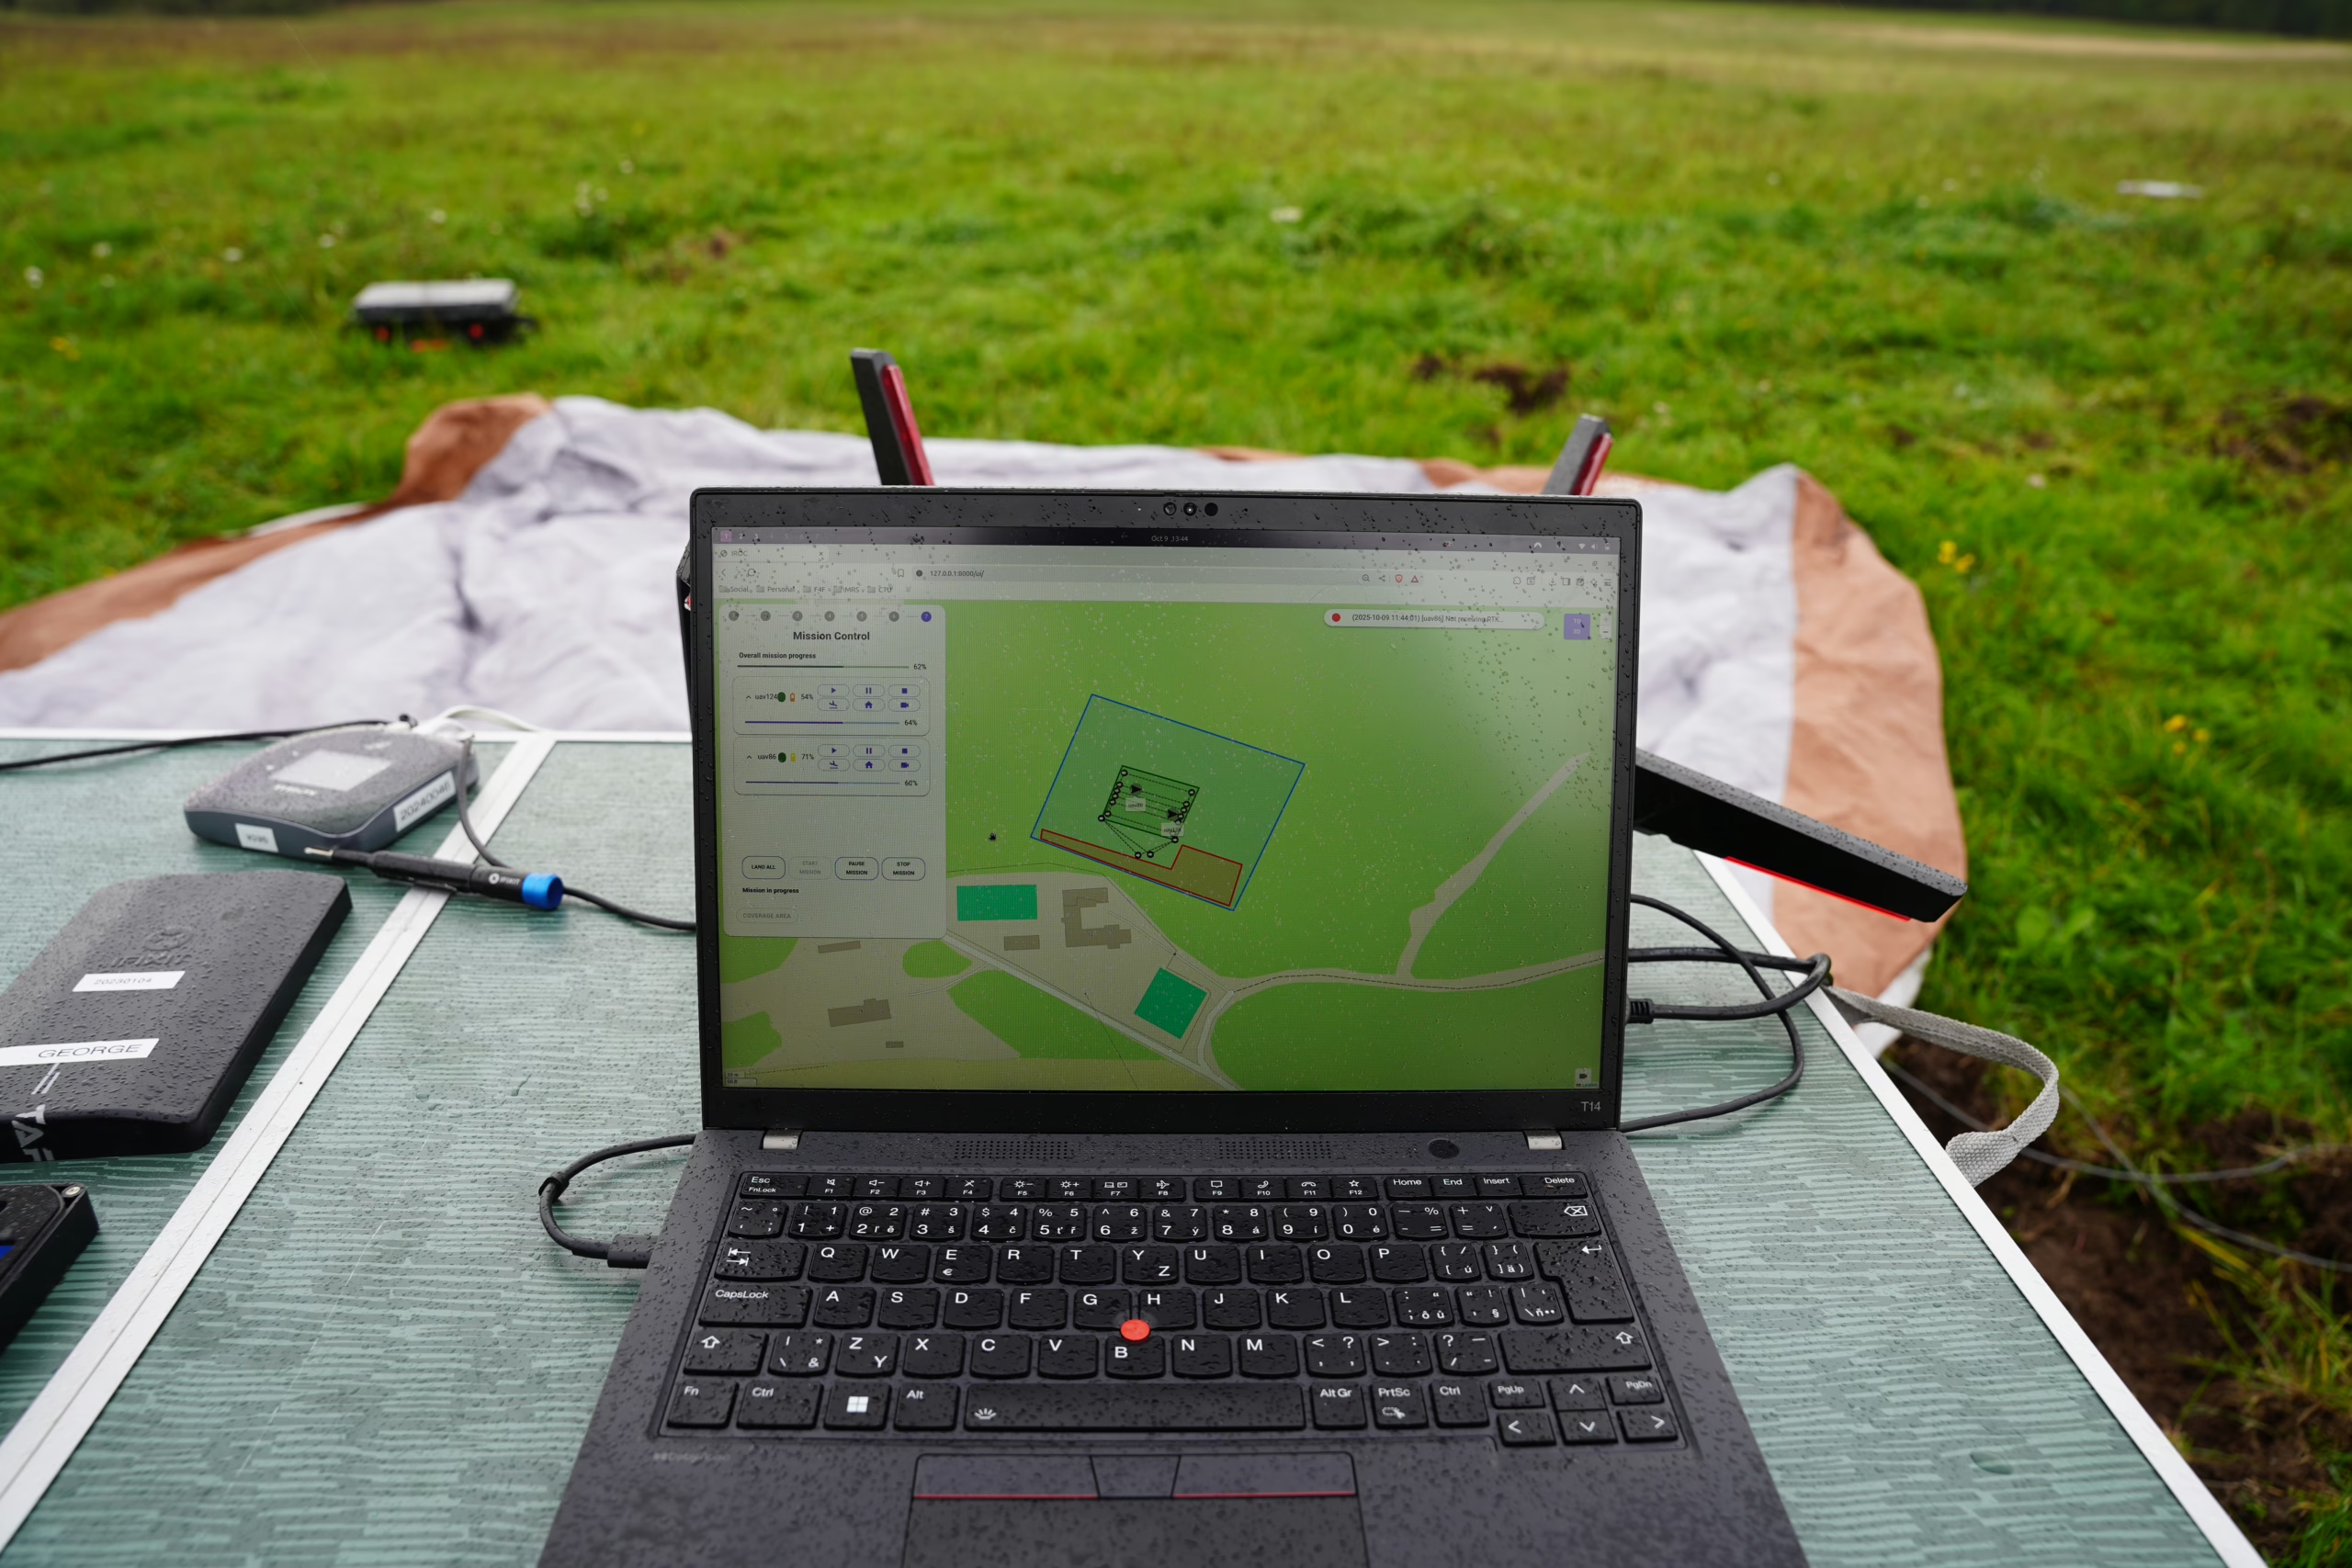
See the Project Outcomes
Robotic system demonstrator with integrated developed modules.
Support software for planning routes and visualizing telemetry and sensory data for diverse teams of robots.
Project Funding
This project is co-financed from the state budget by the Technology agency of the Czech Republic under the SIGMA Progamme – funding programme for applied research and innovation.
Project Partners
Partners: VUT Brno

Project Details
Project ID: TQ03000786
Programme: SIGMA – DC 2: Začínající výzkumníci/výzkumnice a vyrovnávání příležitostí v projektech aplikovaného výzkumu, Program na podporu aplikovaného výzkumu a inovací
Time Period: 01/2024 – 12/2025
AeroSTREAM
AeroSTREAM: Strengthening Research and Innovation Excellence in Autonomous Aerial Systems

AI Flying Robot for Safe Capture of Unauthorized Drones
EU co-funded project aiming to create AI-equipped flying robot for safe capture of unauthorized drones in protected space

Autonomous Air and Ground Robots

Autonomous Solar Park Maintenance
System for automated monitoring and maintenance of solar parks employing artificial intelligence and unmanned aerial platforms.
We Help You to Establish Flying Robots’ Research/Lab
From modular drones to tailored software and field-tested platforms, we help you build and scale your research in autonomous flying systems.
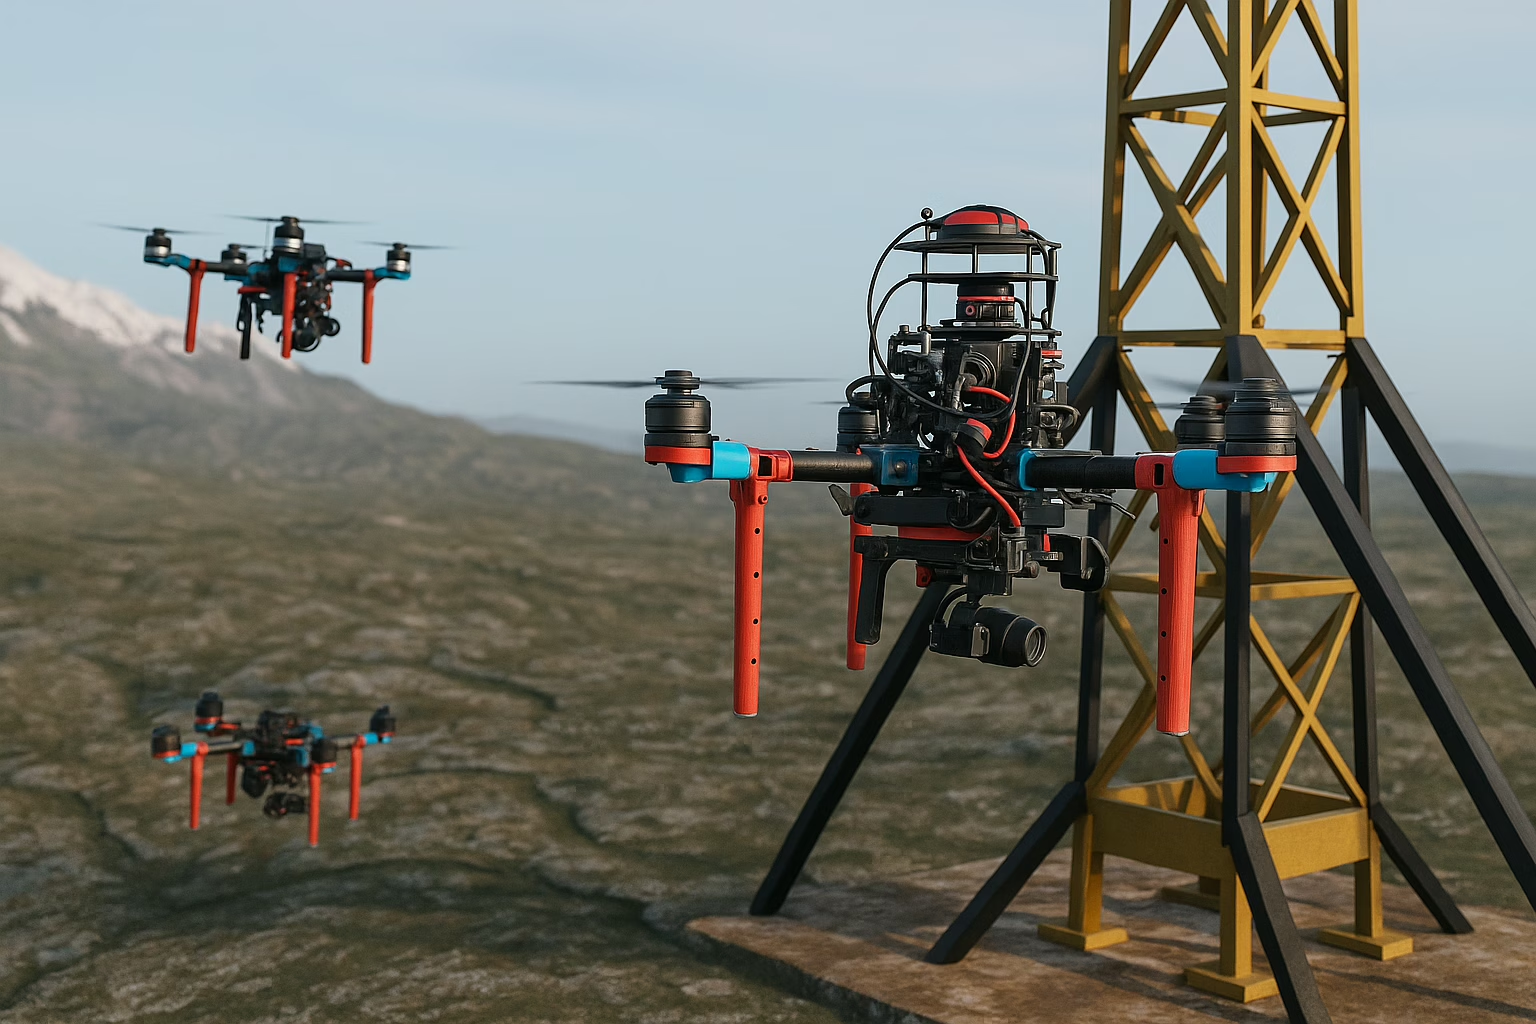
Multi-Robot Aerial System for Autonomous Surveillance and Inspection
Multi-robot aerial system for autonomous surveillance and inspection of large industrial complexes resistant to communication and GNSS signal failures.